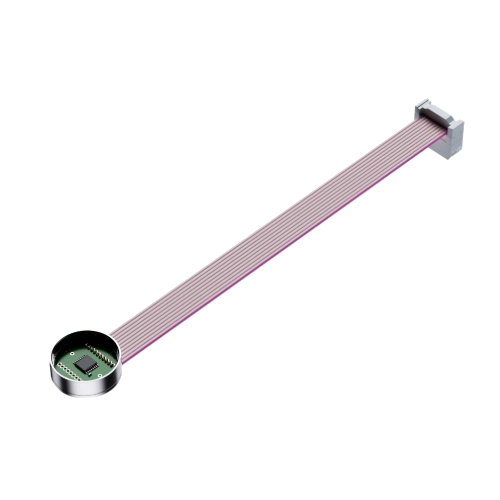
FA-Φ24mm Built-in Servo Driver
FA-Φ24mm built-in servo drive unit is specially matched with Φ24 coreless BLDC motors. Embedded rear structure omits separate external driver, adopts 3-phase FOC control to achieve ultra-precise triple closed-loop control, supports MODBUS RS485 and pulse direction dual control signals.
・Matching Motor: Φ24 two-pole coreless BLDC motors
・Control Algorithm: 3-Phase FOC Vector Control
・Dual Interfaces: RS485 MODBUS + TTL Pulse & Direction
・Operating Voltage: DC 7~36V
・Nominal Current: 3A
・Operating Temperature: -20℃ ~ +80℃
Mechanical Dimensions
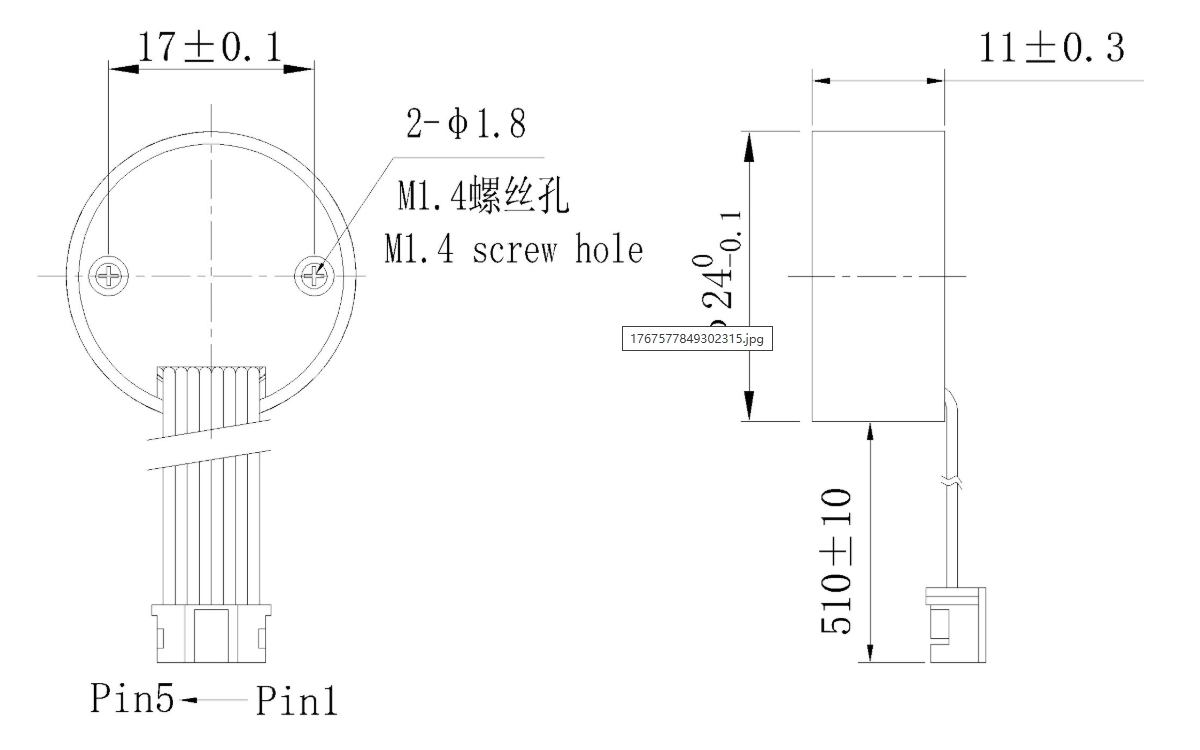
Dimensions are in mm. Please refer to the datasheet for tolerances and mounting details.
Performance Parameters
| Servo driver specifications | |||
|---|---|---|---|
| Operating voltage | DC 7~36V | Speed control accuracy | ±0.5% |
| Nominal current | 3A | Current control accuracy | ±5mA |
| Minimum speed unit | 0.01RPM | Minimum position control unit | 0.01° |
| Minimum current unit | 1mA |
485 Interface
| 485 interface | |
|---|---|
| Maximum voltage | 5V |
| MODBUS Protocol | |
| Maximum baud rate | 921600 |
| Transmission distance | 20meters |
Pulse & Direction interface TTL
| Pulse & Direction interface TTL | |
|---|---|
| Allows input of pull-up voltage | 5V |
| Maximum pulse frequency | 1MHz |
| Transmission distance | >2M |
Terminal data
| Terminal data | ||||
|---|---|---|---|---|
| Terminal model | Pin 1 ~ Pin 5 | JST PHR-5Pin PH2.0 AWG26 PE | ||
| Pin 1 + 黑Black | Pin 2 + 红色Red | Pin 3 空白 not connected 白色White | Pin 4 A(485通讯口)蓝色Blue | Pin 5 B(485通讯口)黄色Yellow |
Other specifications
| Other specifications | |
|---|---|
| Operating temperature range | -20…+80℃ |
| Rotation direction | CW-View onto motor front shaft |
Engineering Overview
Core Advantages
- Embedded integrated design, no external driver needed, greatly simplify equipment structure and wiring;
- Dual communication interfaces (MODBUS RS485 + Pulse/Direction) compatible with mainstream motion controllers;
- 3-phase FOC vector control, ultra-high precision speed, position and torque closed-loop control;
- Real-time data feedback: angle, speed, current, voltage, temperature and operating status;
- Multiple safety protection mechanisms to avoid motor and driver damage under abnormal conditions.
Typical Applications
• Miniature robot joints & robotic dexterous hands
• Portable medical precision drive equipment
• Compact handheld polishing & engraving power tools
• Small optical focusing and micro automation rotary modules